IEEE ITSC 2026
Sep. 2026, Naples, Italy
Together with Jorge Villagra and Abdallah Hossam from the Autopia program, I attended the 29th IEEE International Conference on Intelligent Transportation Systems (ITSC 2026) in Naples, Italy 🇮🇹 (September 15–18), one of the key international forums for research and innovation in intelligent transportation systems.
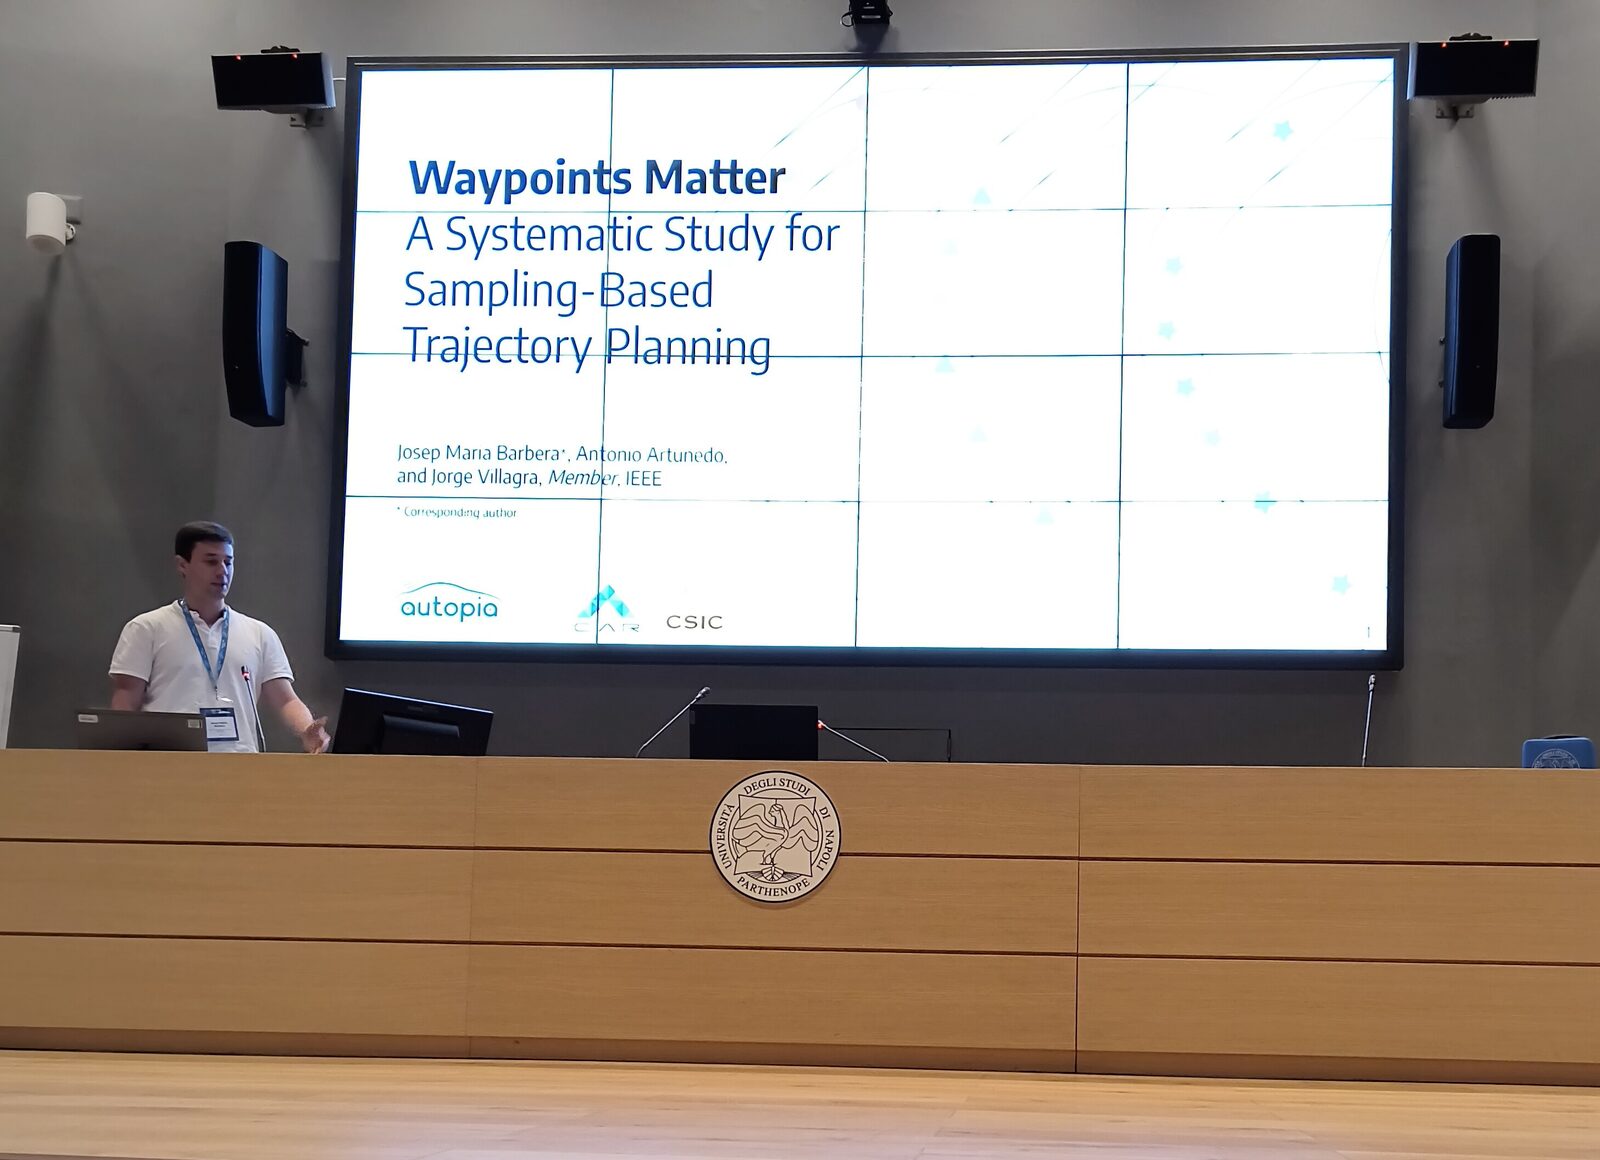
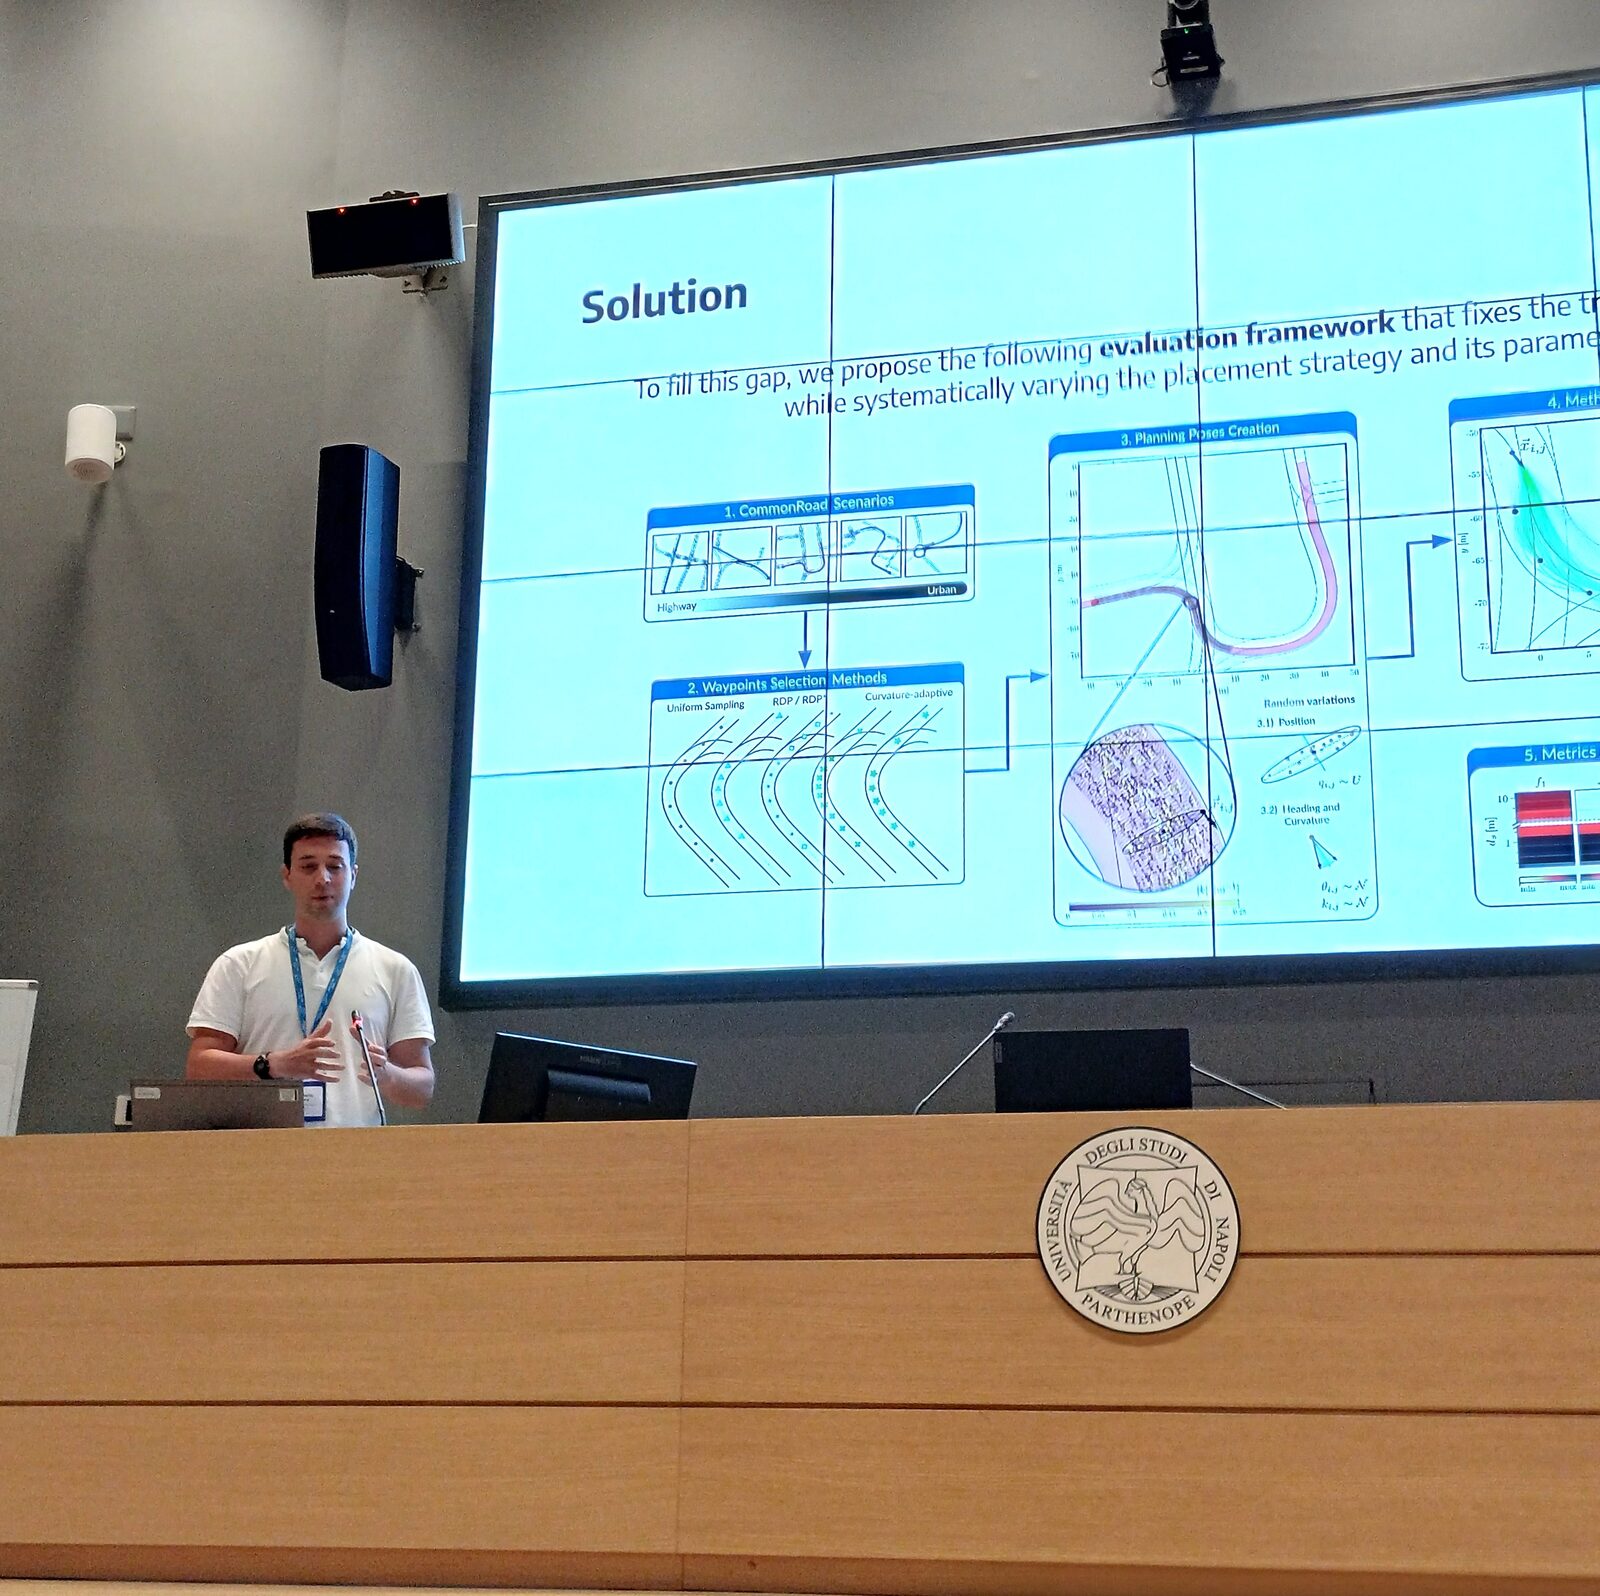
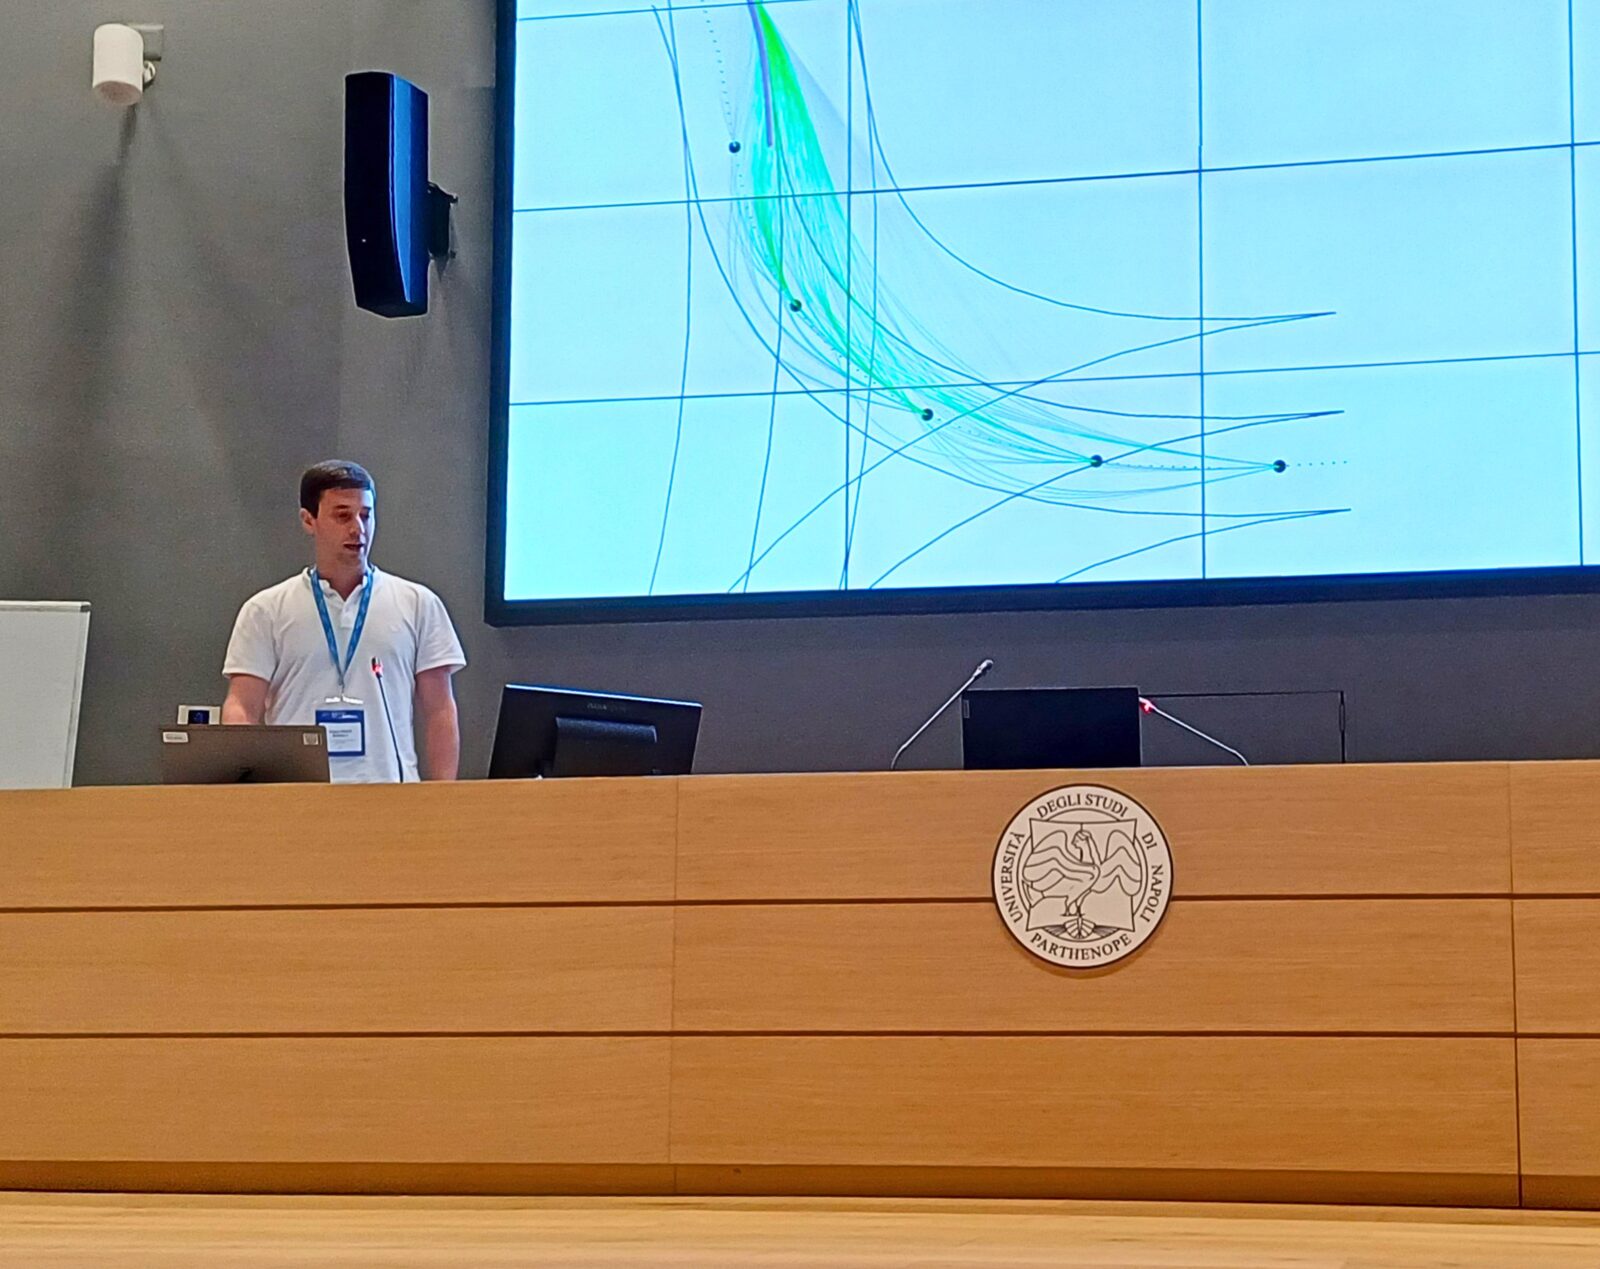
I had the privilege to present our paper Waypoints Matter: A Systematic Study for Sampling-Based Trajectory Planning, co-authored with my advisors Antonio Artuñedo and Jorge Villagra. Our work looks at something often overlooked: where to place the waypoints used to generate candidate trajectories, and how this seemingly simple design choice impacts planner reliability and performance. The findings confirm that simple, well-tuned approaches can outperform more complex strategies, a useful reminder in our field.
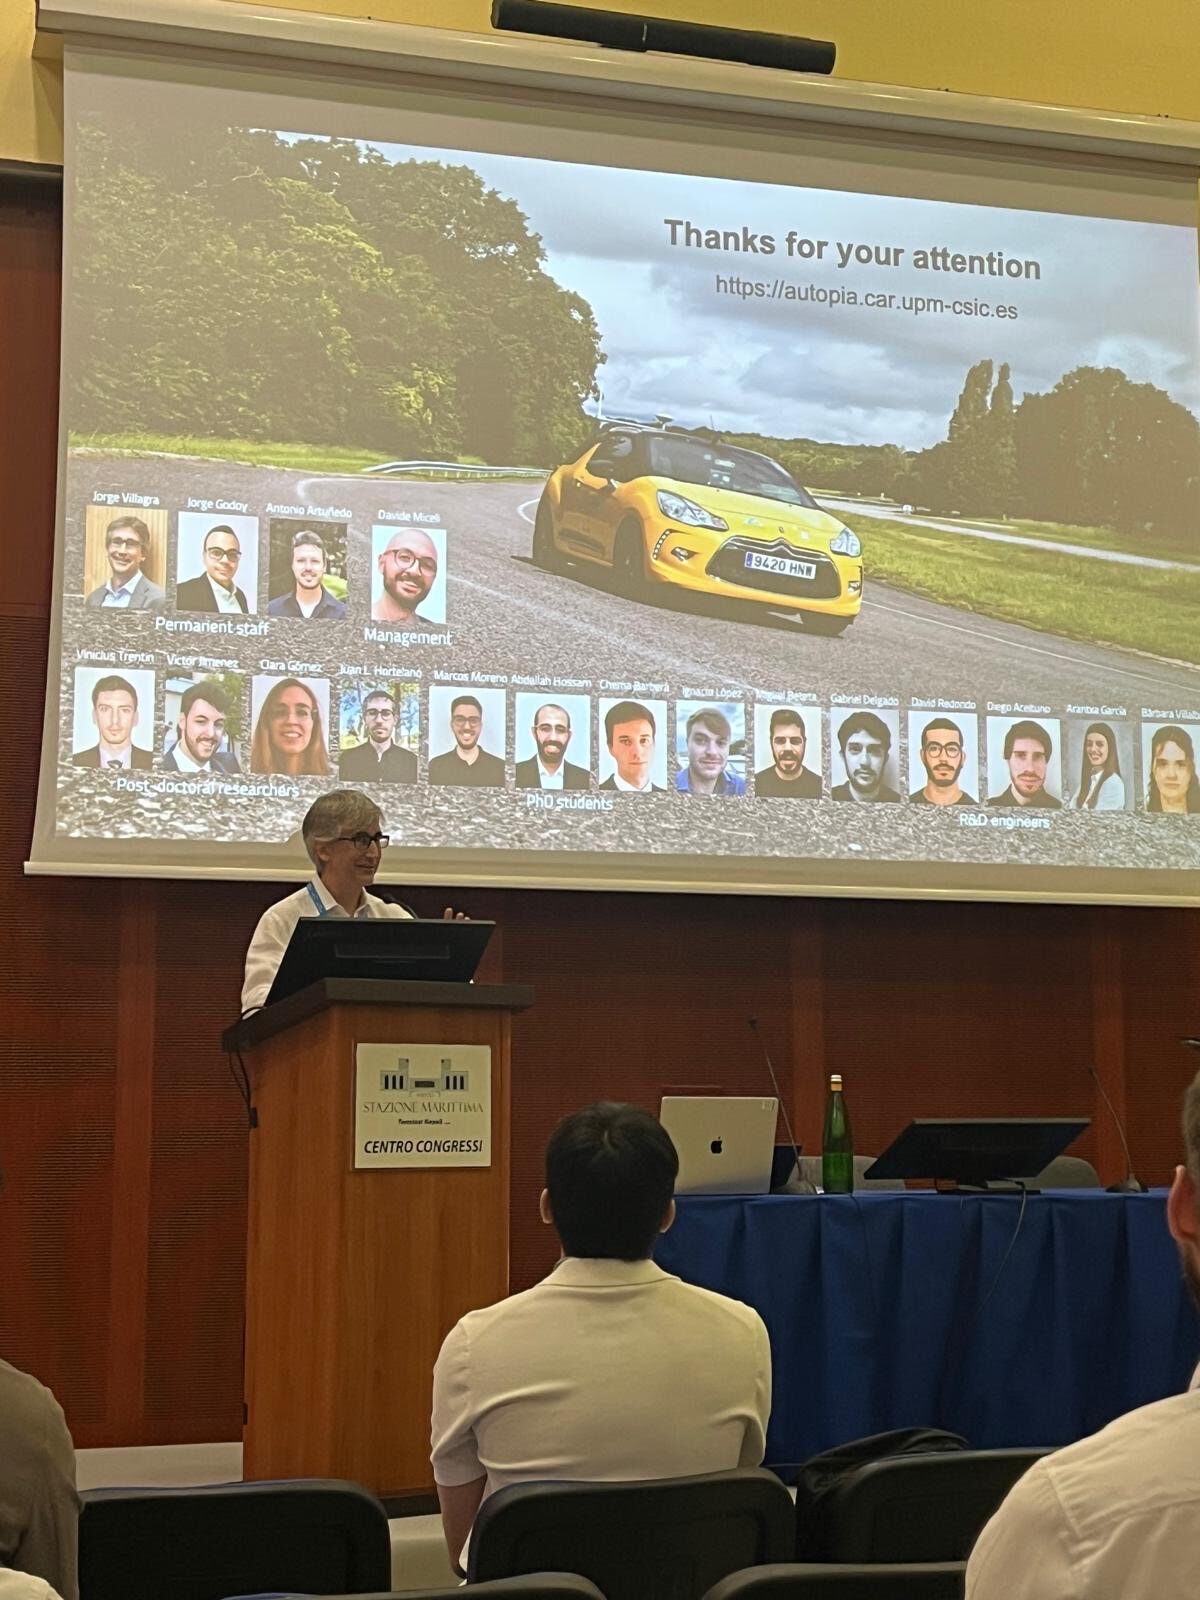
Jorge was also invited to give a keynote at the Interaction-driven Behavior Prediction and Planning for Autonomous Vehicles workshop. His talk, “Navigating what might happen: Structured reasoning for interaction, uncertainty and risk in urban driving”, explored how autonomous vehicles can reason and plan in complex urban environments, where uncertainty and interaction with other road users are unavoidable.
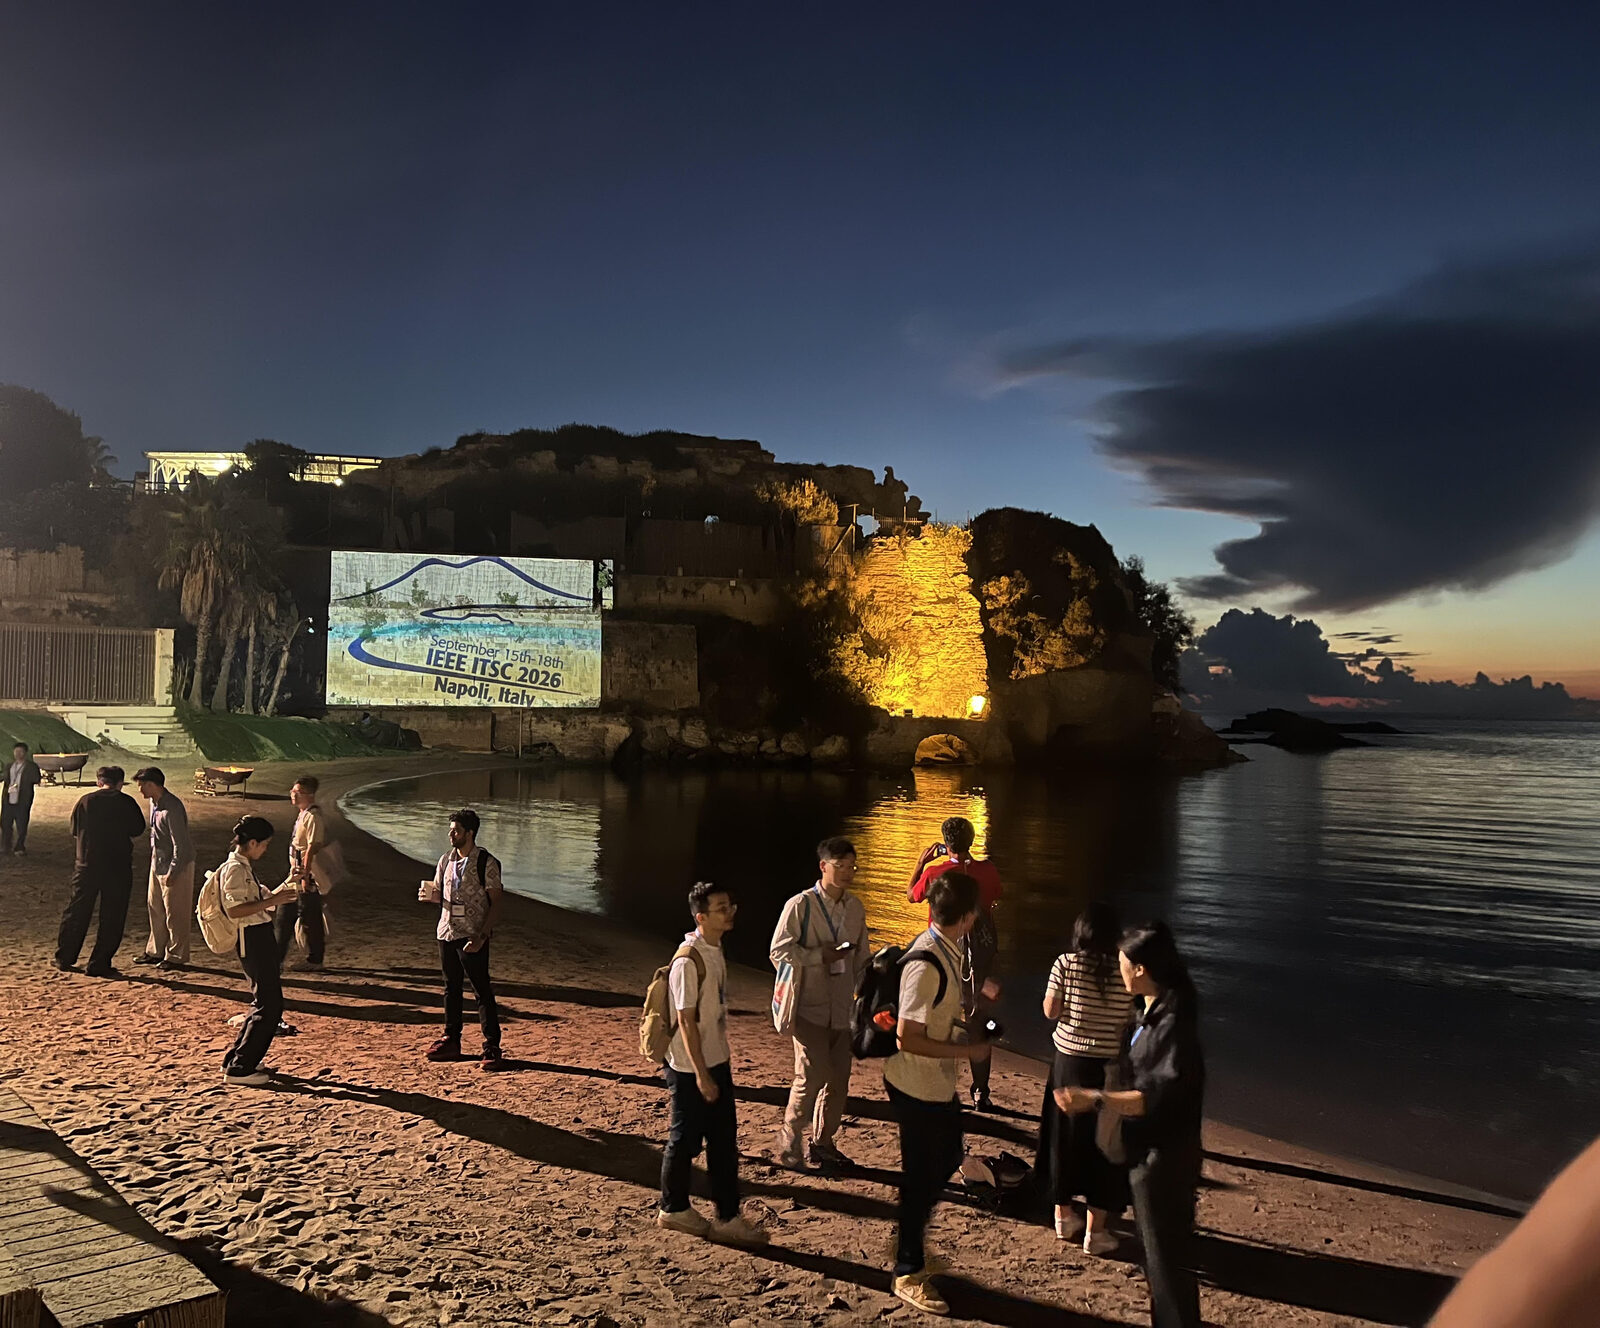
The conference covered a wide range of topics, from cooperative driving to scenario generation. Beyond the technical programme, ITSC was an excellent setting to connect with researchers tackling similar challenges from different angles. I came back from Naples with valuable insights for our next research directions.
Here is my certificate of attendance: